Open-Source Drone Stack
A programmable drone SDK and command center on PX4 and ROS 2.
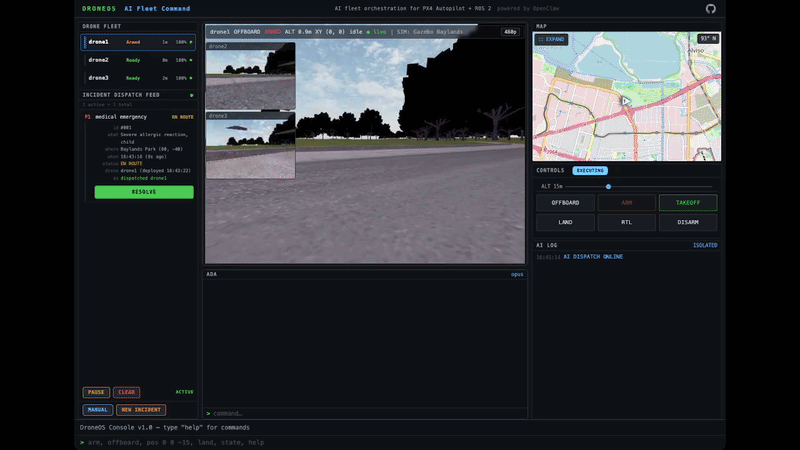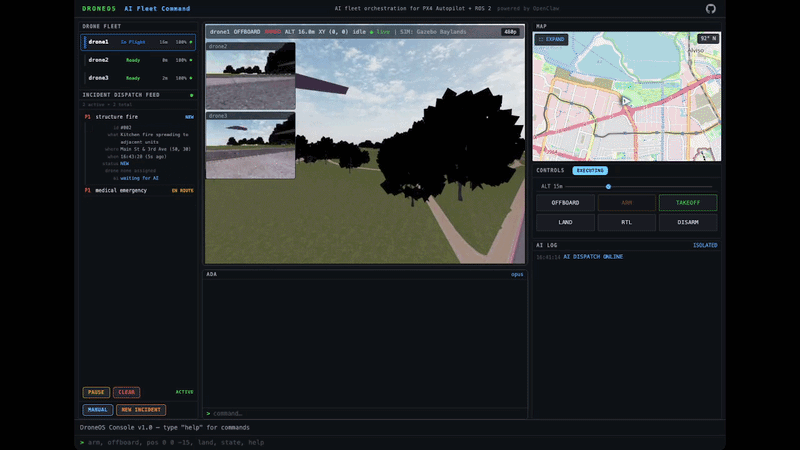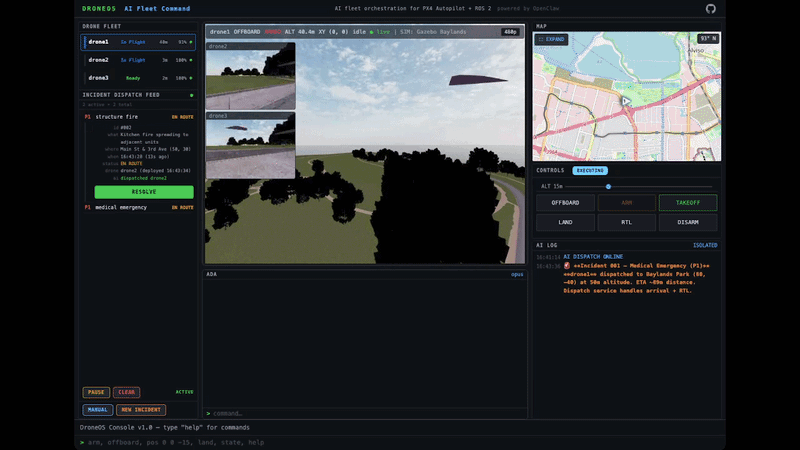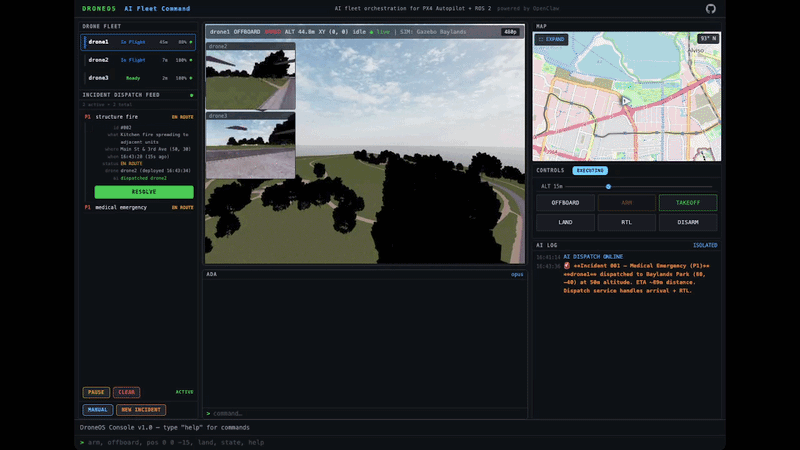
Run the command center on any server, and fly simulated or real PX4 drones from Python, the CLI, the web UI, or an AI agent through the API, CLI, or MCP.
Architecture
PX4 flies the aircraft. DroneOS makes it programmable.
Keep flight-critical stabilization and failsafes in PX4 while exposing clean interfaces for telemetry, mission plugins, operator control, and autonomous dispatch.
C++ & Python SDK
High-level ROS 2 services in drone_core and a Python SDK + CLI for arming, takeoff, navigation, orbits, patrols, and state inspection.
Command Center & Fleet API
Run the command center on any server. Operators and scripts share one API with pilot control holds, geofences, live telemetry, and flight logs.
Jobs as Plugins
Extend what drones do with self-contained job plugins—Patrol, Dispatch, Inspect, Search, and Follow—installed live without restarting the stack.
AI Agent Ready
An AI agent on the same box can fly drones and dispatch missions through the Fleet API, the droneos CLI, or the MCP server.
Simulation First
Develop and verify missions end-to-end in PX4 SITL and Gazebo before flying real aircraft.
Real Hardware
Move the exact same control model to a Pixhawk flight controller and companion computer over VPN or cellular backhaul.